In progress
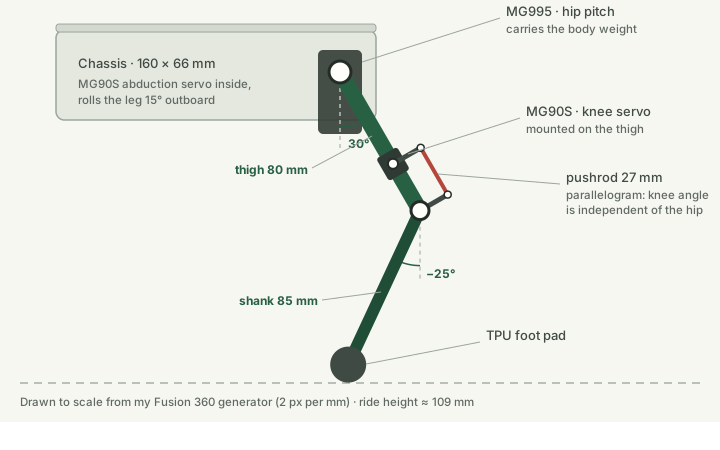
I'm building a four-legged robot with three servos per leg: an MG995 at the hip, and MG90S micro servos for the knee and for swinging the leg out to the side. An ESP32 controls all twelve through a PCA9685 servo board.
The printed parts come from a parametric Fusion 360 script, so changing a leg length or a servo pocket means editing one number and regenerating. The full robot is 26 printed parts, about 175 g of filament.
I started with a single test leg. The ESP32 runs the hip and knee through a walking cycle: lift the foot, swing forward, put it down, push back. Each move eases in and out along a cosine curve so the leg doesn't jerk. Next is getting all four legs walking together.
Parts
- ESP32 dev board
- PCA9685 16-channel servo driver
- 4 MG995 servos (hips)
- 8 MG90S micro servos (knees and side swing)
- 2S LiPo and a 5–6 V BEC for the servos
- PLA/PETG printed parts, TPU feet
Code
This is the single-leg test. The hip servo is on channel 0 of the PCA9685 and the knee on channel 1.